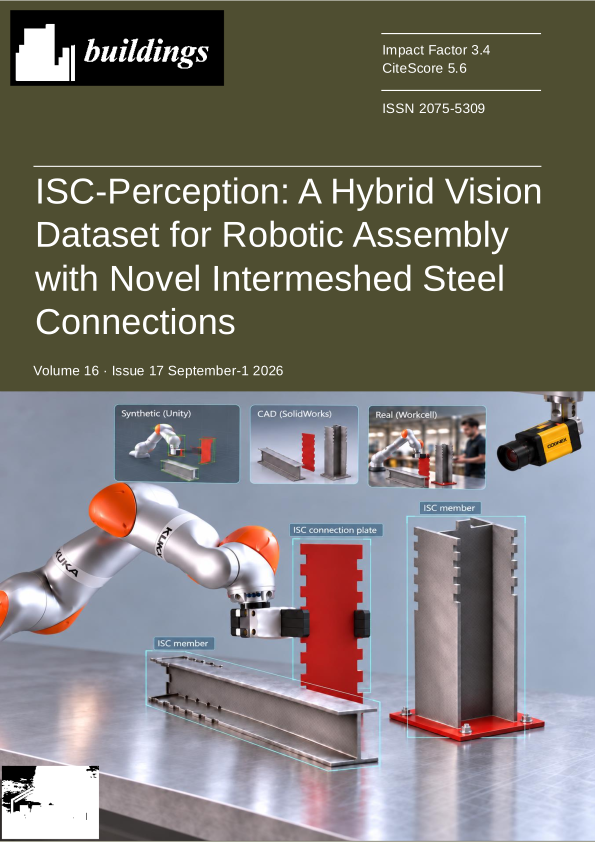
June 2026
ConPose published in Machine Vision and Applications
ConPose presents a jointly trained RGB framework for component detection and pose estimation in robotic structural assembly.
2026
Technical work on LLM observability and LLMOps
Through ISx4 AI Research, I co-authored work on trace-level observability for production LLM applications and operating practices for lean AI product teams.
2025
Robotic ISC assembly strategy presented at ISARC 2025
The paper sets out a collaborative human-robot strategy and experimental platform for automated assembly of Intermeshed Steel Connections.
2025
SLYKLatent published in IEEE Transactions on Human-Machine Systems
The paper develops self-supervised facial representation learning and patch-aware gaze estimation.
2024
QUB-PHEO published in IEEE Access
QUB-PHEO provides multi-view visual data for intention inference in collaborative assembly, covering 70 participants and 36 subtasks.