2022
Hand-Eye-Object
Gaze, hand and object motion combined with temporal learning for intention inference.
Paper ↗Machine learning · computer vision · intelligent systems
I am Dr Samuel Adebayo, a machine-learning researcher and computer scientist at Queen's University Belfast, where I completed my PhD in Computer Science and now work as a Research Fellow. My research began with visual perception and human-machine interaction, studying how gaze, hand motion and object interaction can support intention inference in collaborative tasks. Through ARISE, my current academic work extends this into machine learning and computer vision for robotic structural assembly within a US-Ireland collaboration involving Queen's, New York University, the University of Galway and the University of Texas at San Antonio.
My route into research has also been shaped by engineering and applied data work. Before and alongside academia, I worked across industrial engineering, automation and energy, including TotalEnergies, Procter & Gamble and Hayat Kimya. More recently, I have worked on production AI through ISx4 and Deloitte, including agentic workflows for Air Canada, with emphasis on evaluation, observability, policy-aware decision-making and human escalation. I also teach machine learning and analytics at Belfast Metropolitan College.
Across these settings, I am interested in how intelligent systems extract useful state from imperfect observations, act on that information and remain reliable enough for real-world use. That interest now spans computer vision, multimodal and temporal learning, embodied intelligence, LLMs and agentic systems.

Research Fellow, Queen's University Belfast
Lecturer, Belfast Metropolitan College
Principal Data Scientist, ISx4
The research has expanded from modelling human intent in collaborative tasks to perception for robotic assembly, while retaining the same concern: extracting useful state from incomplete observations and knowing when that state is reliable enough to support a decision.
Gaze, hand and object motion combined with temporal learning for intention inference.
Paper ↗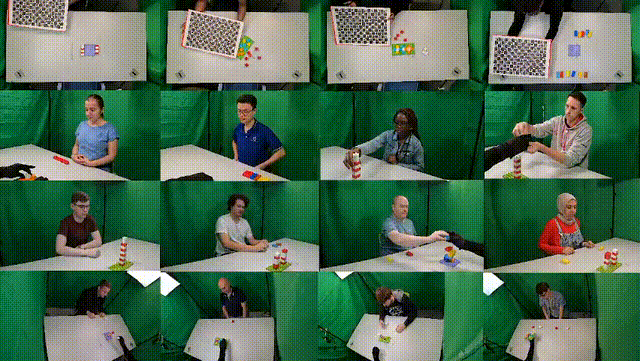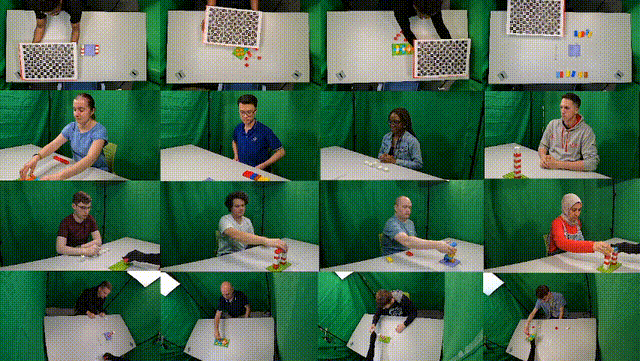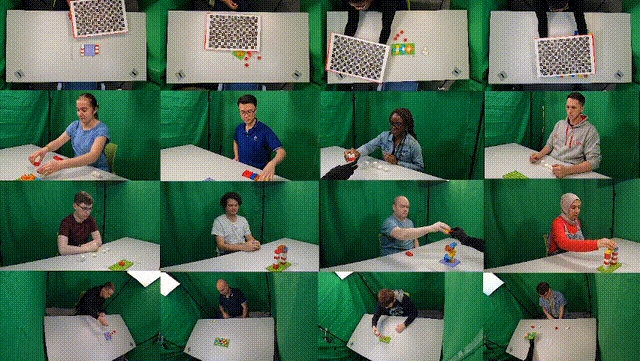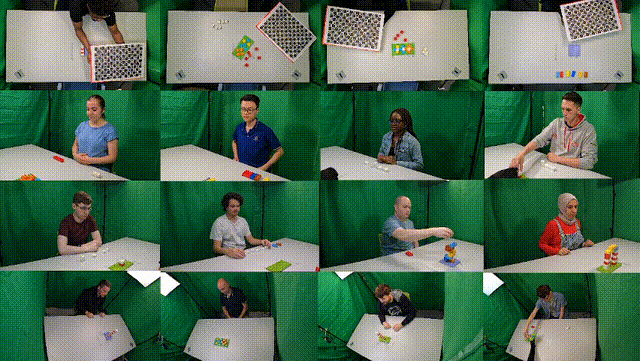
A multi-view dataset for engagement and intention inference in collaborative assembly.
Paper ↗Self-supervised facial representation learning for non-invasive gaze estimation.
Paper ↗ConPose, ISC-Perception and robotic assembly research within ARISE.
ARISE research →Extending the work towards systems whose actions can be evaluated, bounded and escalated when evidence is insufficient.
Research direction →I am a Research Fellow at Queen's University Belfast on ARISE, a US-Ireland collaboration with New York University, the University of Galway and the University of Texas at San Antonio. I lead machine-learning and computer-vision research within the Queen's team.
The work includes ConPose, ISC-Perception and the robotic assembly strategy reported at ISARC 2025.
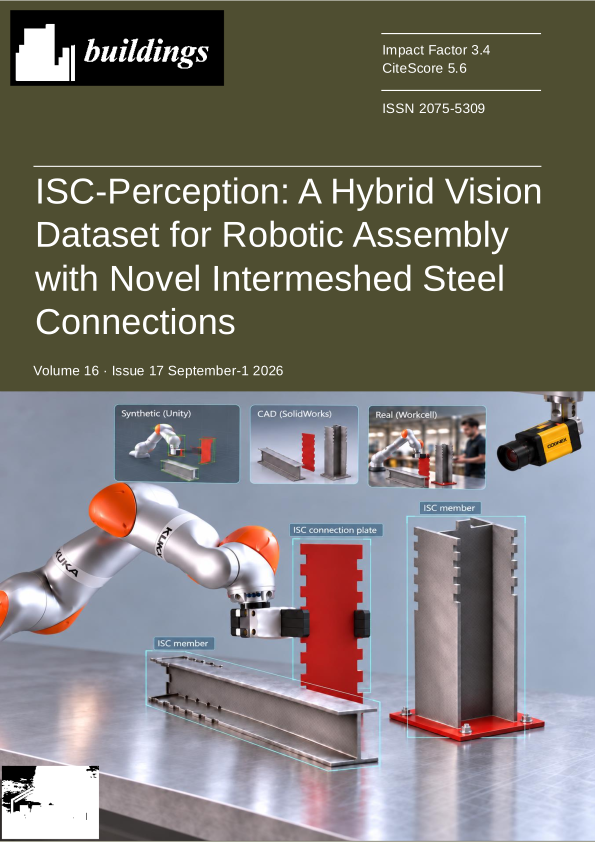
Selected papers showing the breadth of the programme, from collaborative perception to robotic assembly and medical imaging.
Joint RGB detection and pose estimation for robotic structural assembly.
Baseline models for predicting visual motion from the QUB-PHEO dataset.
Deep-learning architectures for early detection and diagnosis of Alzheimer's disease.
Teaching, supervision, peer review and collaborative research sit alongside the publication programme.
Belfast Metropolitan College, with previous teaching across core computer science.
SupervisionBSc, MSc and HLA projectsProjects across robotic perception, pose estimation and human-machine interaction.
Reviewing across human-machine systems, AI, computer vision and pattern recognition.
International academic collaboration alongside industry-facing work on reliable AI systems.